{Kimura}
I am attaching a trend graph with the upper limit of the left vertical axis corrected to 1×10⁻⁴ Pa.
The partial pressure of H₂O shows a downward trend.
{Kimura}
I am attaching a trend graph with the upper limit of the left vertical axis corrected to 1×10⁻⁴ Pa.
The partial pressure of H₂O shows a downward trend.
I tested the automatic Segment production and GauCh analysis as part of the validation of the KAGRA DetChar tools with the latest conda environment.
Overall, both jobs worked well under HTCondor.
The Segment job took 15.5 s on average and up to 25 s to treat 15 minutes data. The memory usage was about 200 MB.
The GauCh job took 116 s on average and up to 136 s to treat one hour data. Its memory usage was about 0.8 GB on average and up to about 1.0 GB.
However, the current test data were taken while the interferometer was not locked, so these resource requirements may be underestimated.
I plan to check the memory usage again after the interferometer is locked and update the requested resources in the HTCondor submit files if necessary.
[Fujimoto, Komori]
We measured the IMC FSR to be 5.6243653(1) MHz, corresponding to an IMC round-trip length of 53.302451(1) m.
To reach the target RF sideband frequency, we will move the MCE by 10.26 mm toward the MCI/MCO.
We tuned the frequency of the seed RF sideband used for the IFO LSC so as to minimize the peak produced by laser-frequency excitation, using the same method as described in klog:23115.
The optimal frequency was found to be 5.6243653(1) MHz, corresponding to an IMC round-trip length of 53.302451(1) m.
This value differs by 13 µm from the previous measurement performed in 2024 (klog:29385).
The target sideband frequency is 5.6265328 MHz.
Therefore, the IMC round-trip length should be shortened by 20.53 mm.
Since the MCE displacement changes the round-trip length by twice the mirror displacement, we will move the MCE by 10.26 mm toward the MCI/MCO.
[Yokozawa, Ushiba, Fujimoto]
We worked on lock recovery and initial alignment for XARM and YARM.
For XARM, we completed the initial alignment, including ADS, after recovering the error signal (klog 37656).
For YARM, I recovered the IR and GR resonances and successfully locked IRY. However, GRY was locked at a point away from resonance, and I could not lock it to the TEM00 mode.
XARM
As described in klog 37656, we successfully recovered the IRX error signal by correcting the LO settings.
Thanks to the XARM alignment performed by Yokozawa-san in the morning, we were able to lock XARM with only minor alignment adjustments and complete the initial alignment procedure, including ADS.
However, as pointed out in klog 37656, some issues still need to be investigated, such as the change in the OLTF gain.
YARM
When I started the initial alignment of YARM, no flashes were observed for either IR or GR.
By adjusting the alignment of SR3, BS, IY, and EY while monitoring the camera images and PD signals, I improved the transmission to approximately 0.8 for both IR and GR and successfully locked IRY.
Fig. 1 shows a screenshot of the setup at that time.
However, when I attempted to lock GRY, it locked at a point away from resonance, as shown in Fig. 2.
As a result, the lock check repeatedly failed, causing the system to attempt to relock GRY.
If anyone has any ideas about what might be causing this issue, I would appreciate your comments at the next morning briefing.
[Fujimoto, Ushiba]
We recovered IRX lock and confirmed that initial alignment of XARM can be done.
However, we found several changes, which needs to be checked.
Since we could not see the PDH signals, we investigated what happens.
First, we checked all circuits are ON after the blackout and confirmed it.
Then, we checked the signals from the LO with an osilloscope and found that the output frequency is 11.248 MHz (double of the IMC FSR).
After several investigation, we noticed frequency REF setting was ON, so we turned it OFF and set the frequency to 5.624365513 MHz.
Then, we could see PDH signals.
We set the LO amplitude to 13dBm because the Harmonic Generator is designed as 13dBm input (JGW-D1808028-v5).
However, IRX could not be locked with this setting and we reduced LO amplitude to 10dBm, and then we could lock the IRX.
Figure 1 shows the OLTF of IRX feedback loop with 10dBm seed LO amplitude.
Though small bump can be seen around UGF, OLTF seems fine.
We also measured the crossover frequency between MCE and laser frequency (fig2).
Crossover frequency is slightly lower but the reason is unknown at this moment.
We also checked the IMC OLTF (fig3) and crossover frequency between PZT and EOM (fig4).
The UGF is about 70kHz, which was 120kHz during O4c (klog35394) but the reason of UGF reduction is unknown.
The crossover frequency between PZT path and EOM path is about 14kHz, which is almost same as before but the phase seems additionally delayed by 6 degrees.
According to the measured results, there seems several changes from before, so we need to check them one by one.
One possible changes is LO setting because the current setting is different from the values, which was taken during the recovery from the planned power outage (notion page).
[Kimura]
I turned on the Q-mass installed in the EXC into operation.
A copy of the trend data for residual gas components is attached for reference.
The total pressure (T.P.) indicated by the Q-mass is 1.33 × 10⁻³ Pa.
Meanwhile, when the Q-mass was started up, the newly installed pressure gauge read 1.3 × 10⁻³ Pa.
[Kimura]
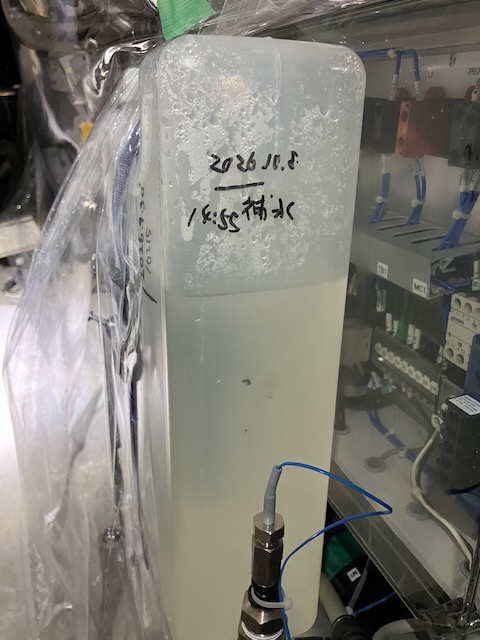
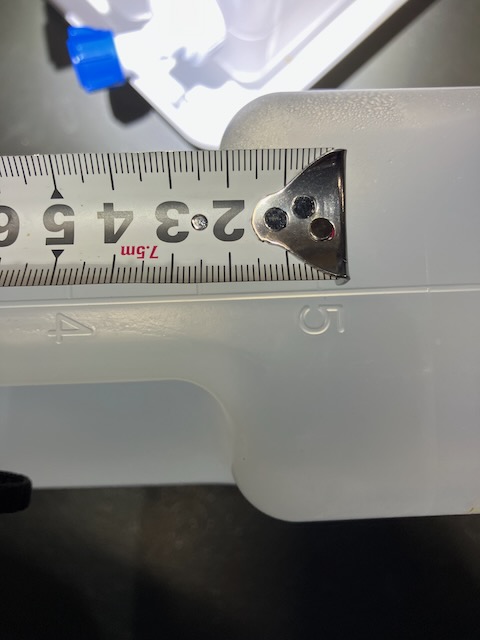
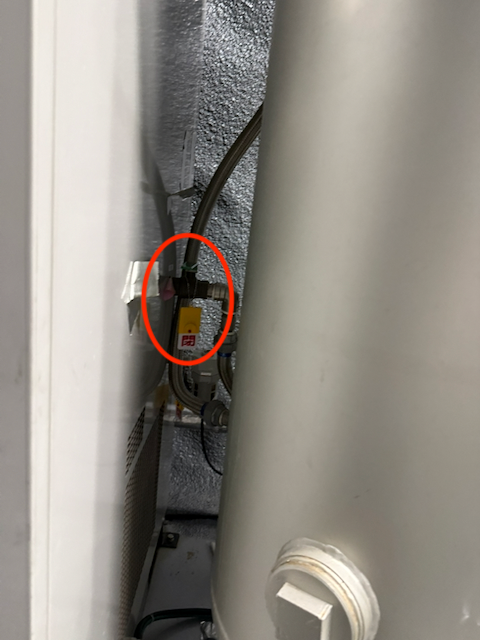
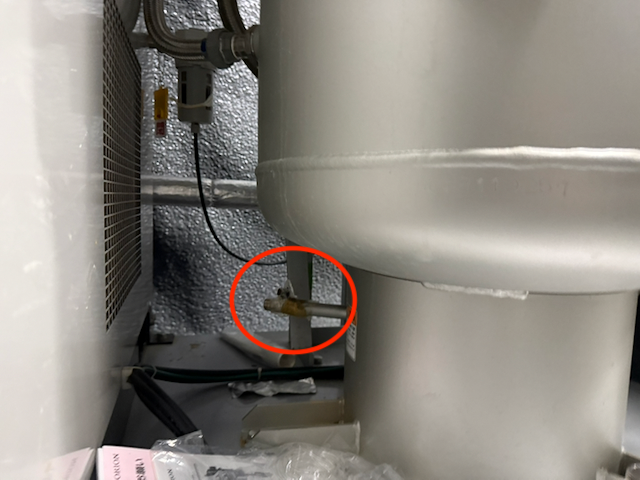
I checked the water level in the cooling water chiller for the X-15 vacuum pumping unit.
The water level had dropped by 50 mm since the last water refill k-log 37632.
(See Photo 1)
The ratio of water volume to water level is 1 L per 50 mm.
(See Photo 2)
The rate of decrease since the last water refill was 7 cc per hour.
We will continue to monitor the situation.
[Uchiyama, Ushiba]
We performed swaping test of ETMX TM H1/H2 actuators.
The place where we swapped the cables this time was just after AI outputs to confirm the actuator efficiency reduction happened at DGS side or coil driver side.
The gain differences due to the cable swapping is ~1dB, so 3dB differences come from both DGS (~1dB) and coild driver side (~2dB).
We conducted cable swap test of ETMX TM H1/H2 actuators to check where the actuator efficiency reduction happens.
This time, we swapped the cable just after AI outputs (between AI and coil driver).
Figure 1 shows the result.
Left and right pannels show the result when H1 and H2 actuators were excited.
Blue and red represents the results before and after swapping.
Black lines shown in the left pannels are the reference measured in 2024.
When we conducted the swapping test just before the vacuum chamber, the gain difference due to the cable swap is ~3dB (klog37636).
The result this time shows the difference of ~1dB, which means the gain difference of 3dB comes from both DGS (~1dB) and coil driver (~2dB).
I offloaded the F0 and F1 GAS filters with the FRs.
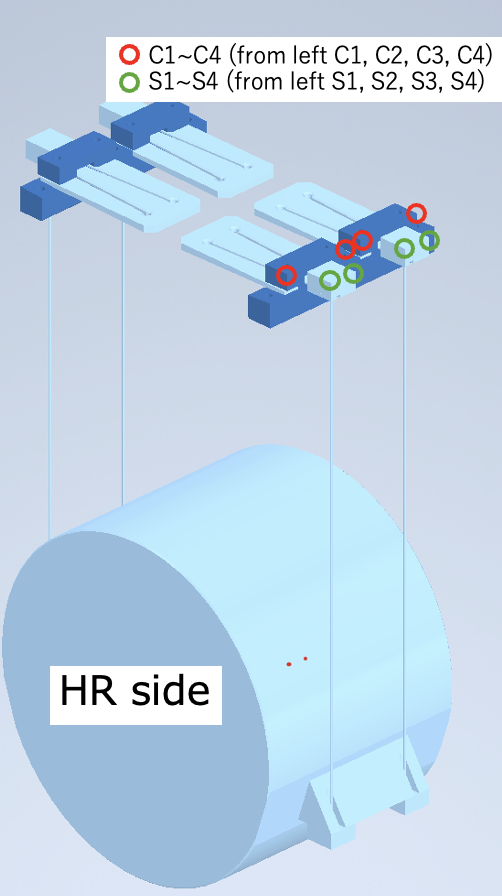
We analysed AB face 1/2 and AC face 1/2, comparing the station baselines, P1/P2 reference frame and S1–S4 coordinates.
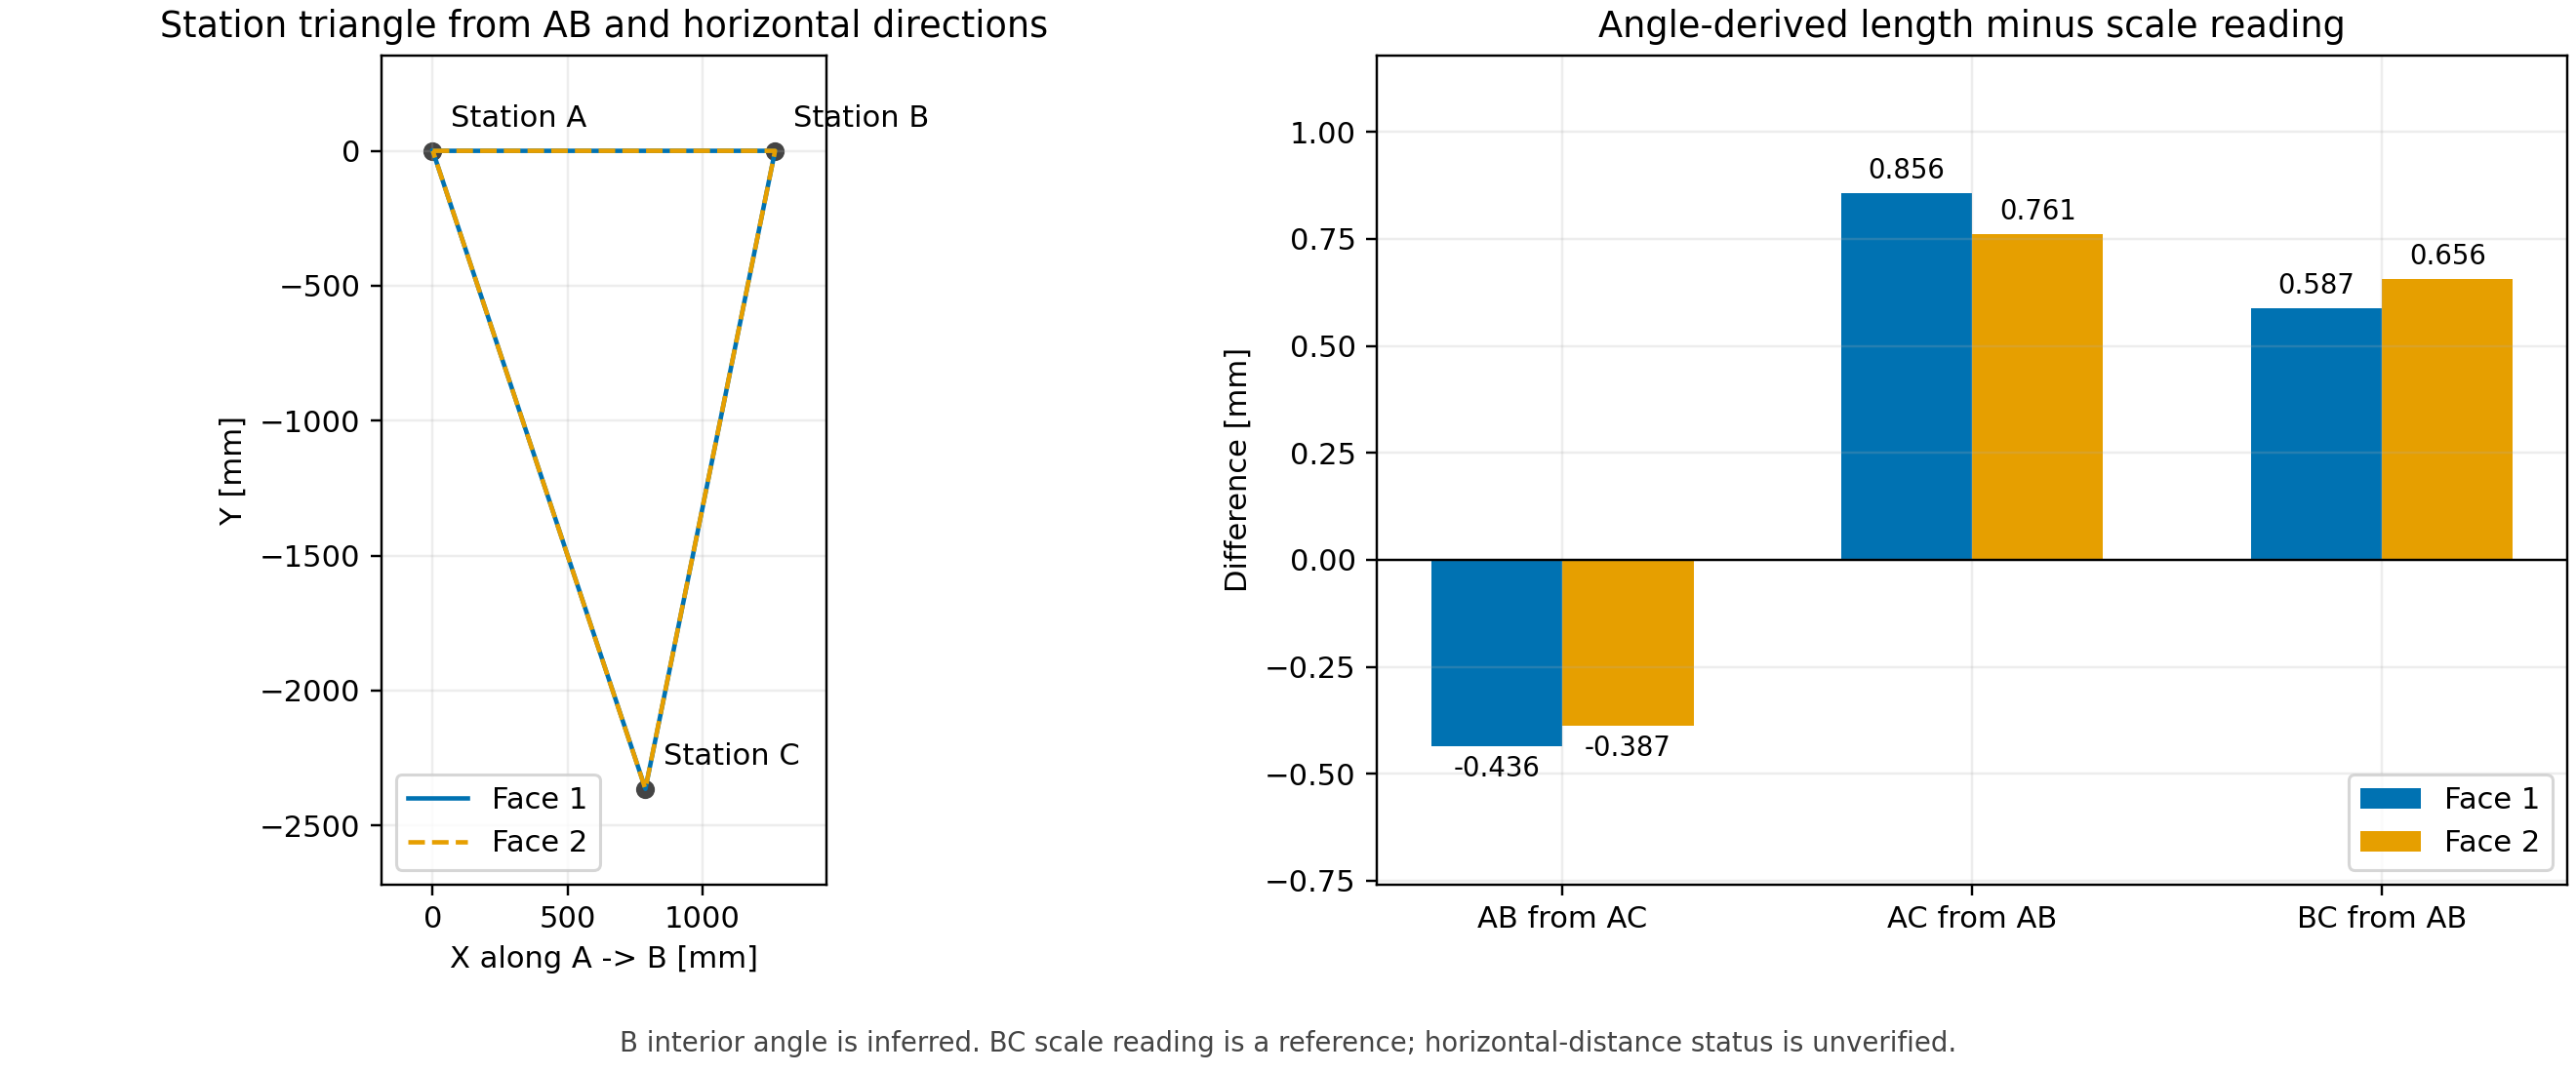
Using AB = 1268.25 mm and the station directions, the calculated AC length exceeded the measured AC = 2491.5 mm by 0.856 mm in face 1 and 0.761 mm in face 2. The station triangle therefore showed sub-millimetre internal agreement.
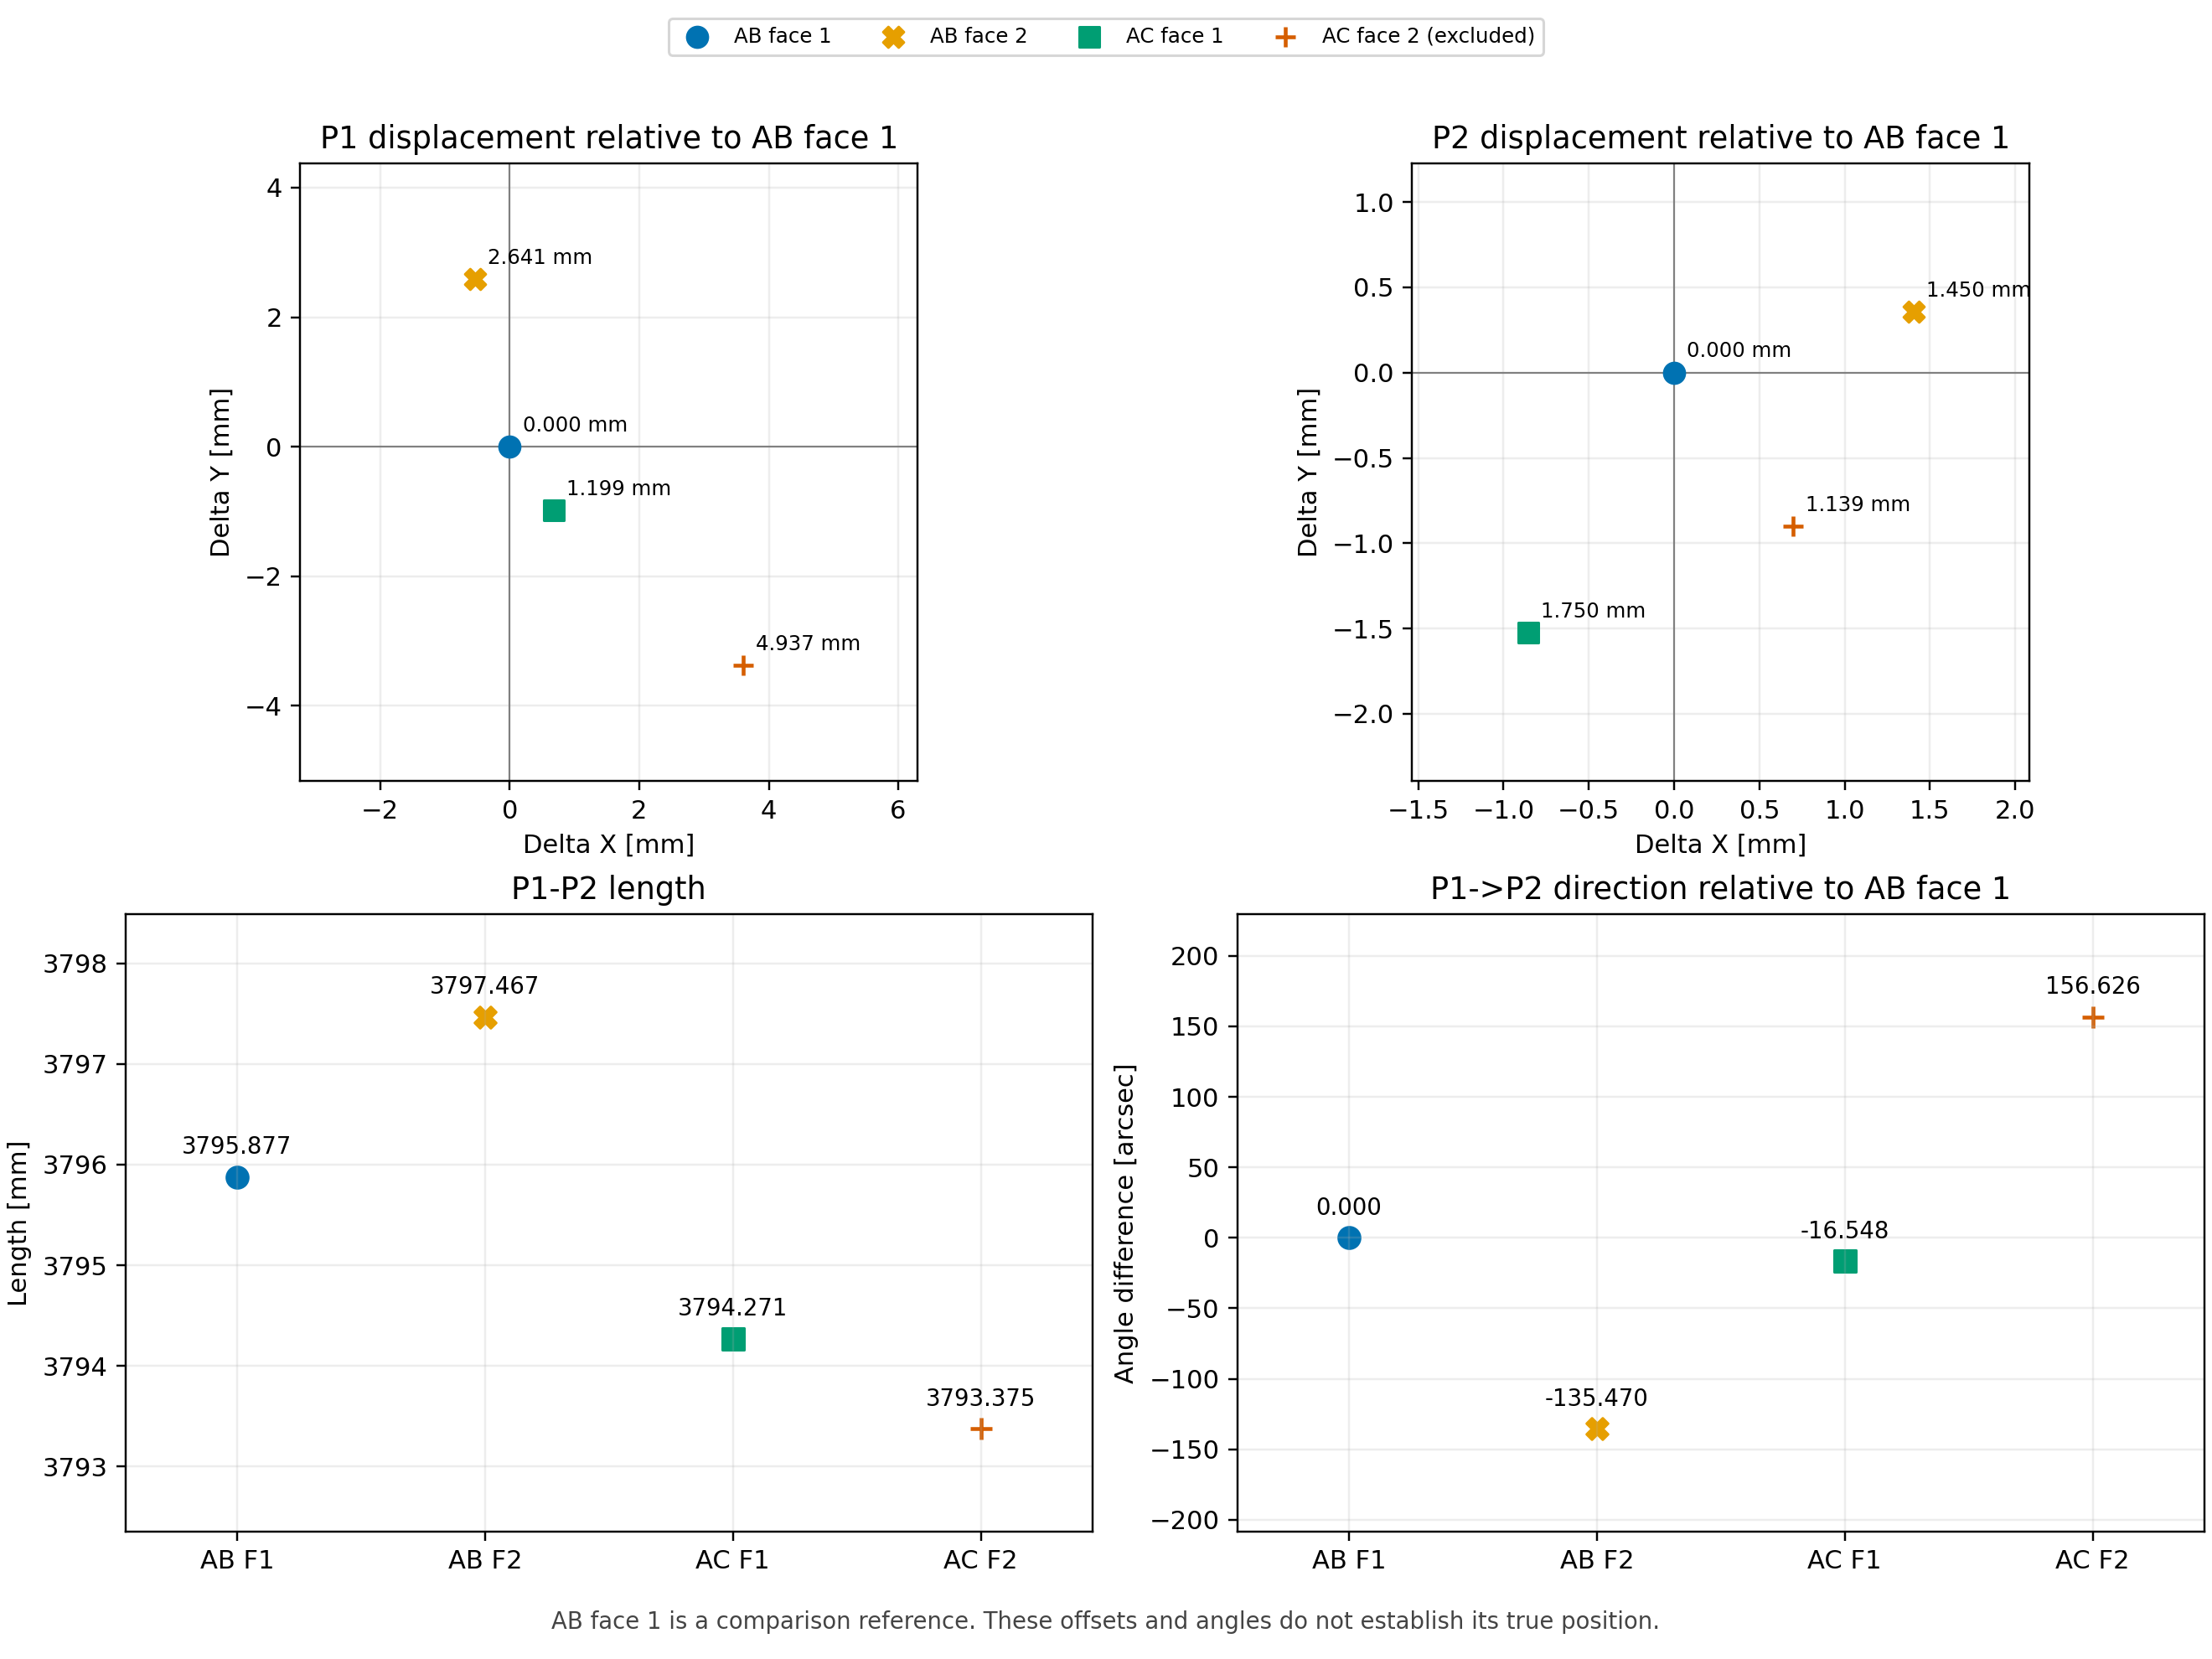
Before alignment, P1 positions and P1→P2 directions were compared in the A-origin/A→B frame. For the three retained reconstructions:
| Series | P1 position difference from AB face 1 [mm] | P1–P2 length [mm] | Direction difference from AB face 1 [deg] |
|---|---|---|---|
| AB face 1 | 0 (reference) | 3795.877 | 0 (reference) |
| AB face 2 | 2.641 | 3797.467 | −0.037630 |
| AC face 1 | 1.199 | 3794.271 | −0.004597 |
The maximum difference in P1–P2 length was 3.196 mm. These are differences between reconstructions; AB face 1 is a comparison reference, not an established true position or direction.
Defining P1 as the origin and P1→P2 as the X axis makes the origin and axis coincide by construction. It does not remove their measurement uncertainty. The MC calculation recomputes P1 and the axis in each trial and propagates their effects into the relative S coordinates.
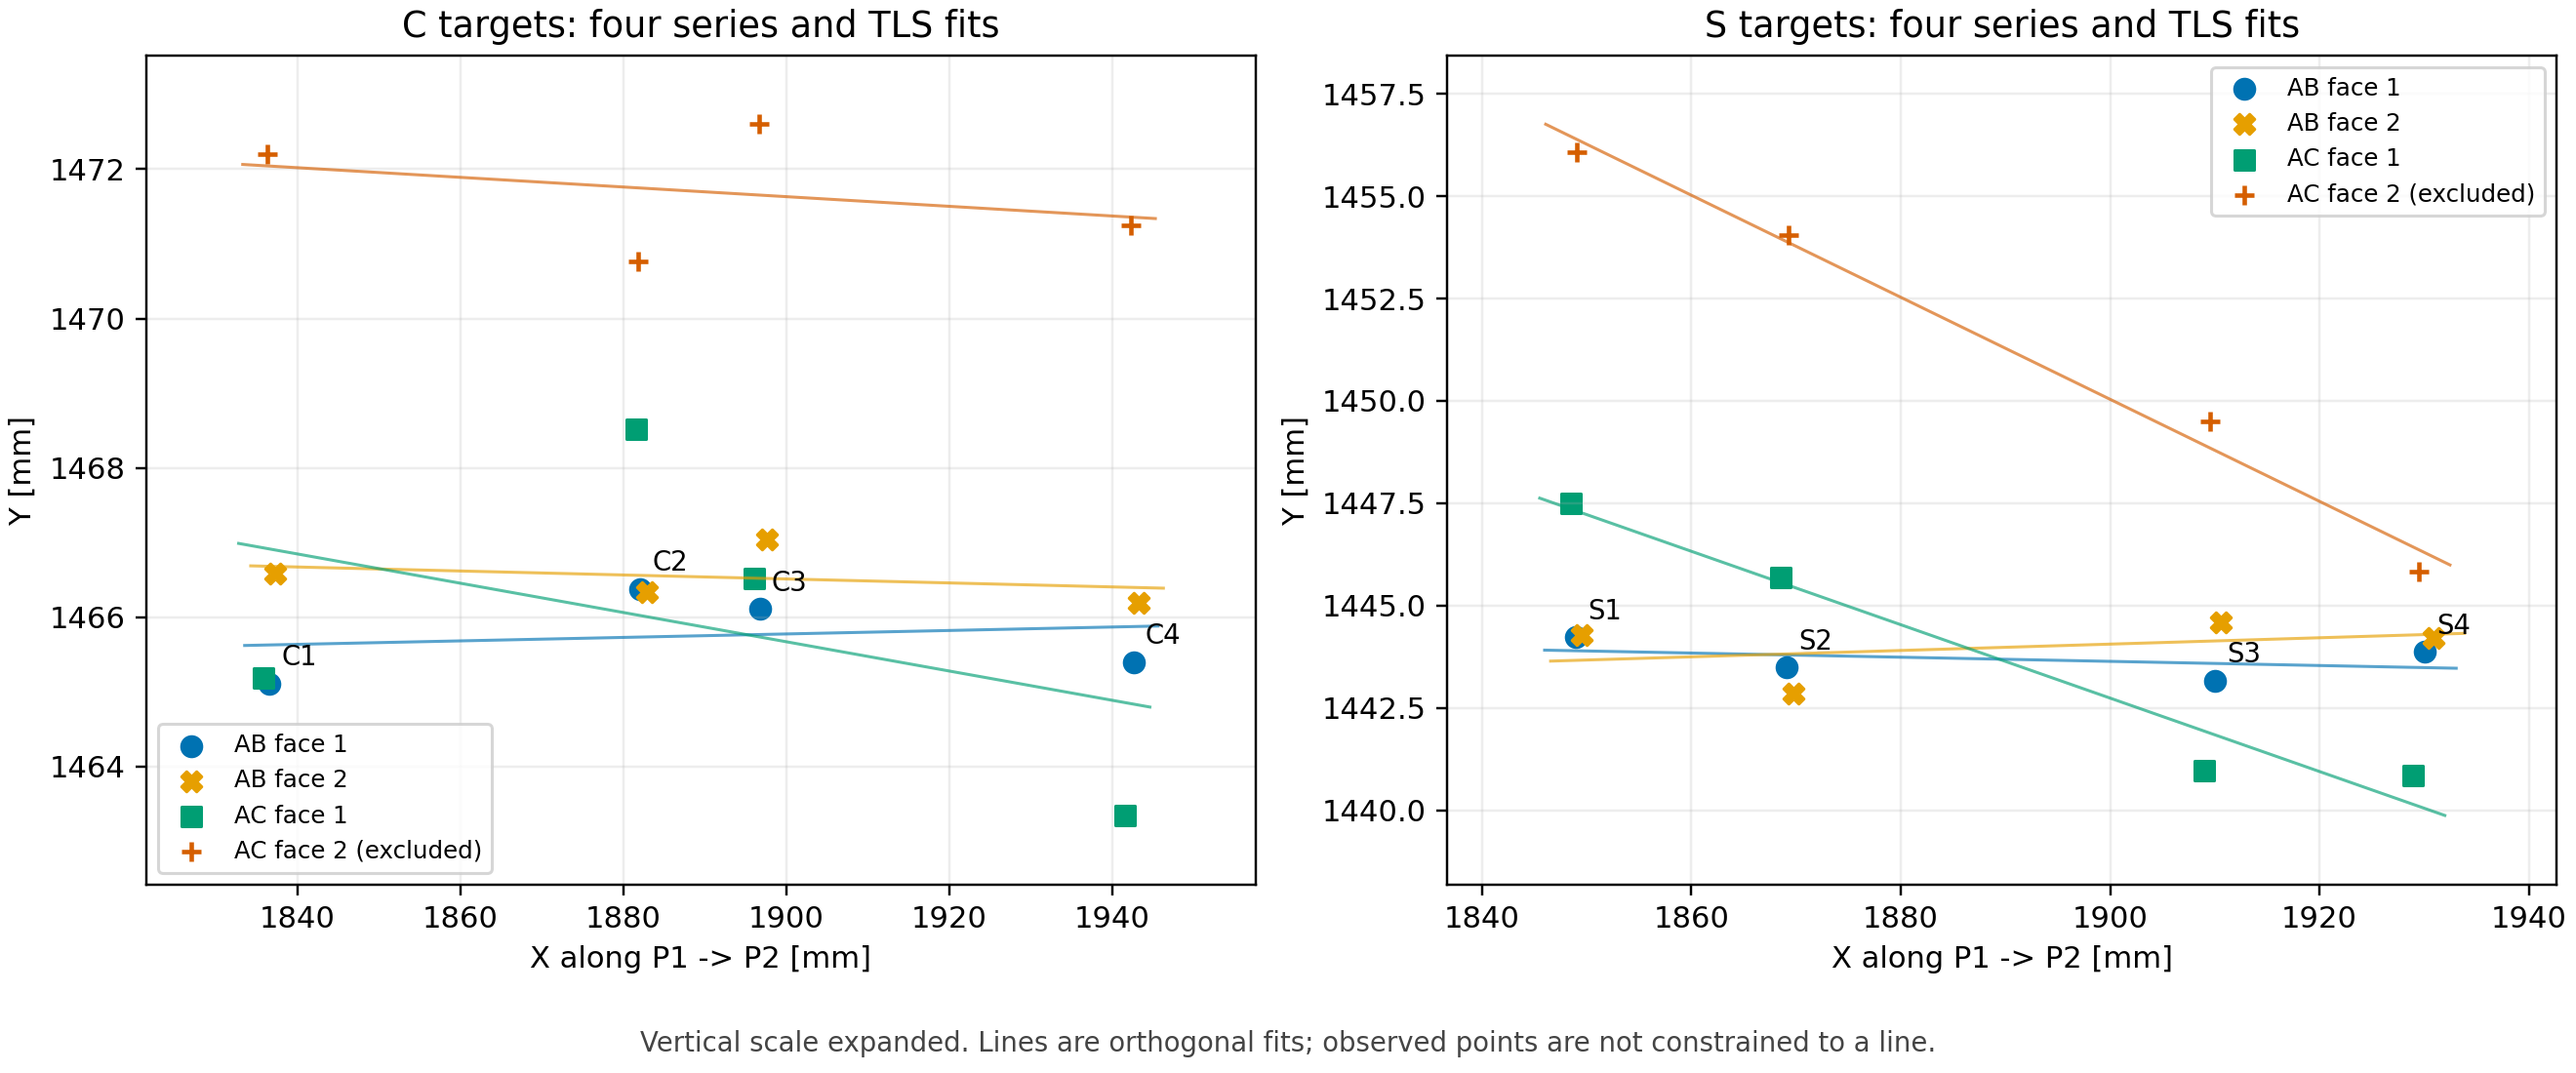
Each reconstruction was transformed to the P1-origin/P1→P2 frame using rotation and translation without scaling. AC face 2 showed the largest overall discrepancies and was excluded from the provisional three-series statistics, while remaining in the diagnostic plots. The responsible observation has not been identified.
| Point | Three-series sample standard deviation [mm] |
|---|---|
| S1 | 1.93 |
| S2 | 1.58 |
| S3 | 1.99 |
| S4 | 2.06 |
Values are the largest standard deviations over horizontal distance directions. They describe series-to-series scatter, rather than maximum errors. Because the reconstructions share observations, these values were not divided by √3.
Both AC faces show a similar S-row trend that differs from AB. The current MC model does not fully explain the configuration difference, so a common effect in the AC reconstruction remains to be investigated.
S/C targets can no longer be reobserved. We plan to remeasure the accessible ABC markers and P1/P2 in both faces, including the previously missing B→C direction and horizontal baseline checks. Provided the relative control-point geometry is unchanged, the new network will test the old baseline and reference directions and allow identifiable corrections to be applied to the existing S/C data.
The 2 mm survey requirement at 1σ has not yet been demonstrated for all S points.
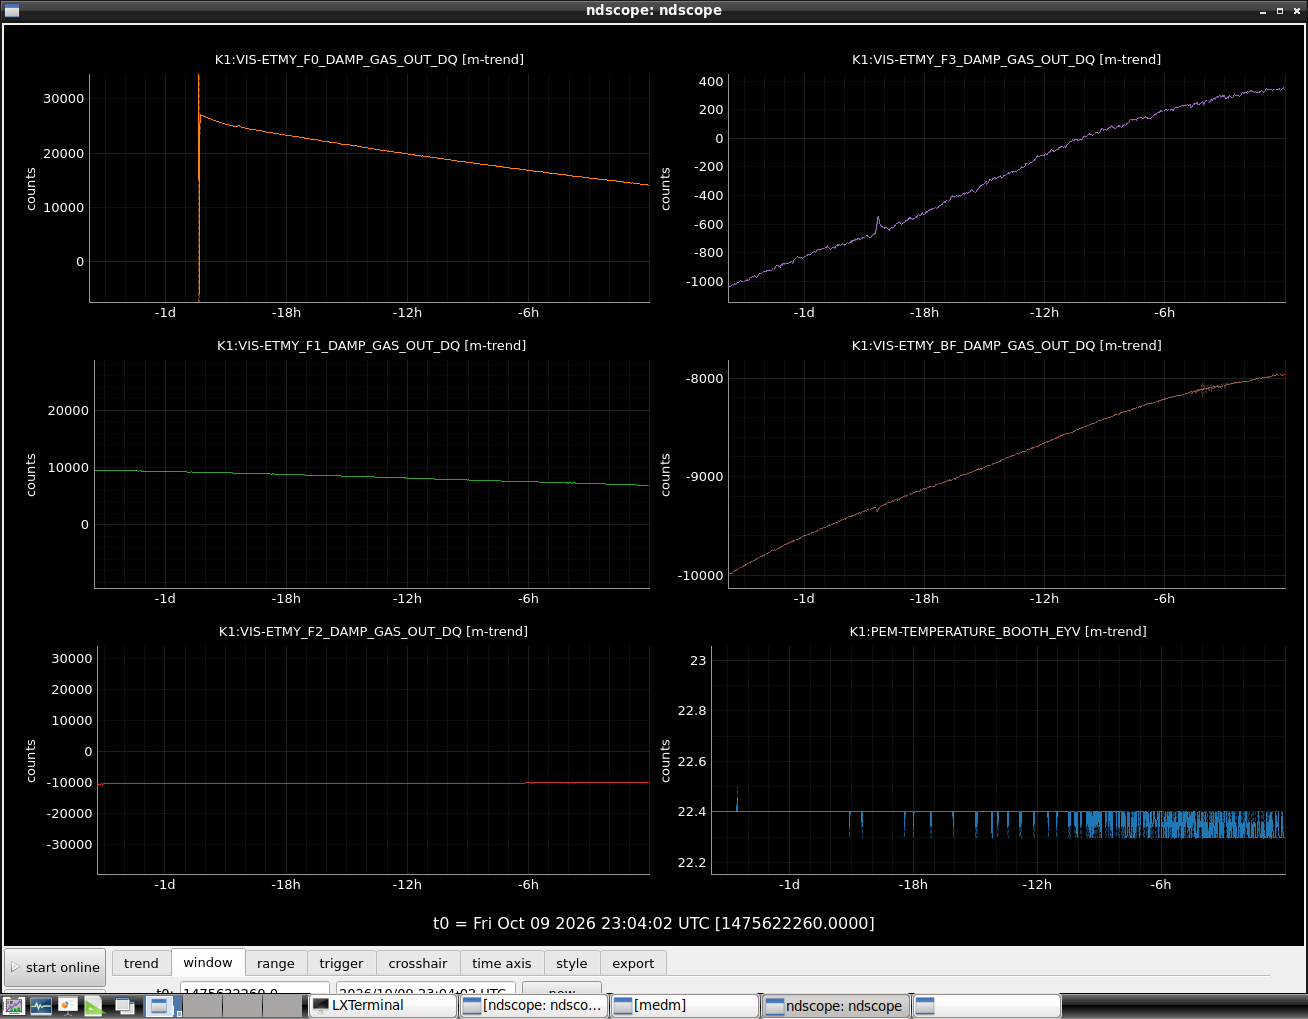
I offloaded the IP and the F0 GAS with the FRs after the pressure reached 16Pa.
In addition, we reduced the number of operated FFU from 2 to 1. Then the EYV temp became ~ 22.4C. Finally, the EY F0 seemed to back around 15000.
This is a follow-up to the previous klog post.
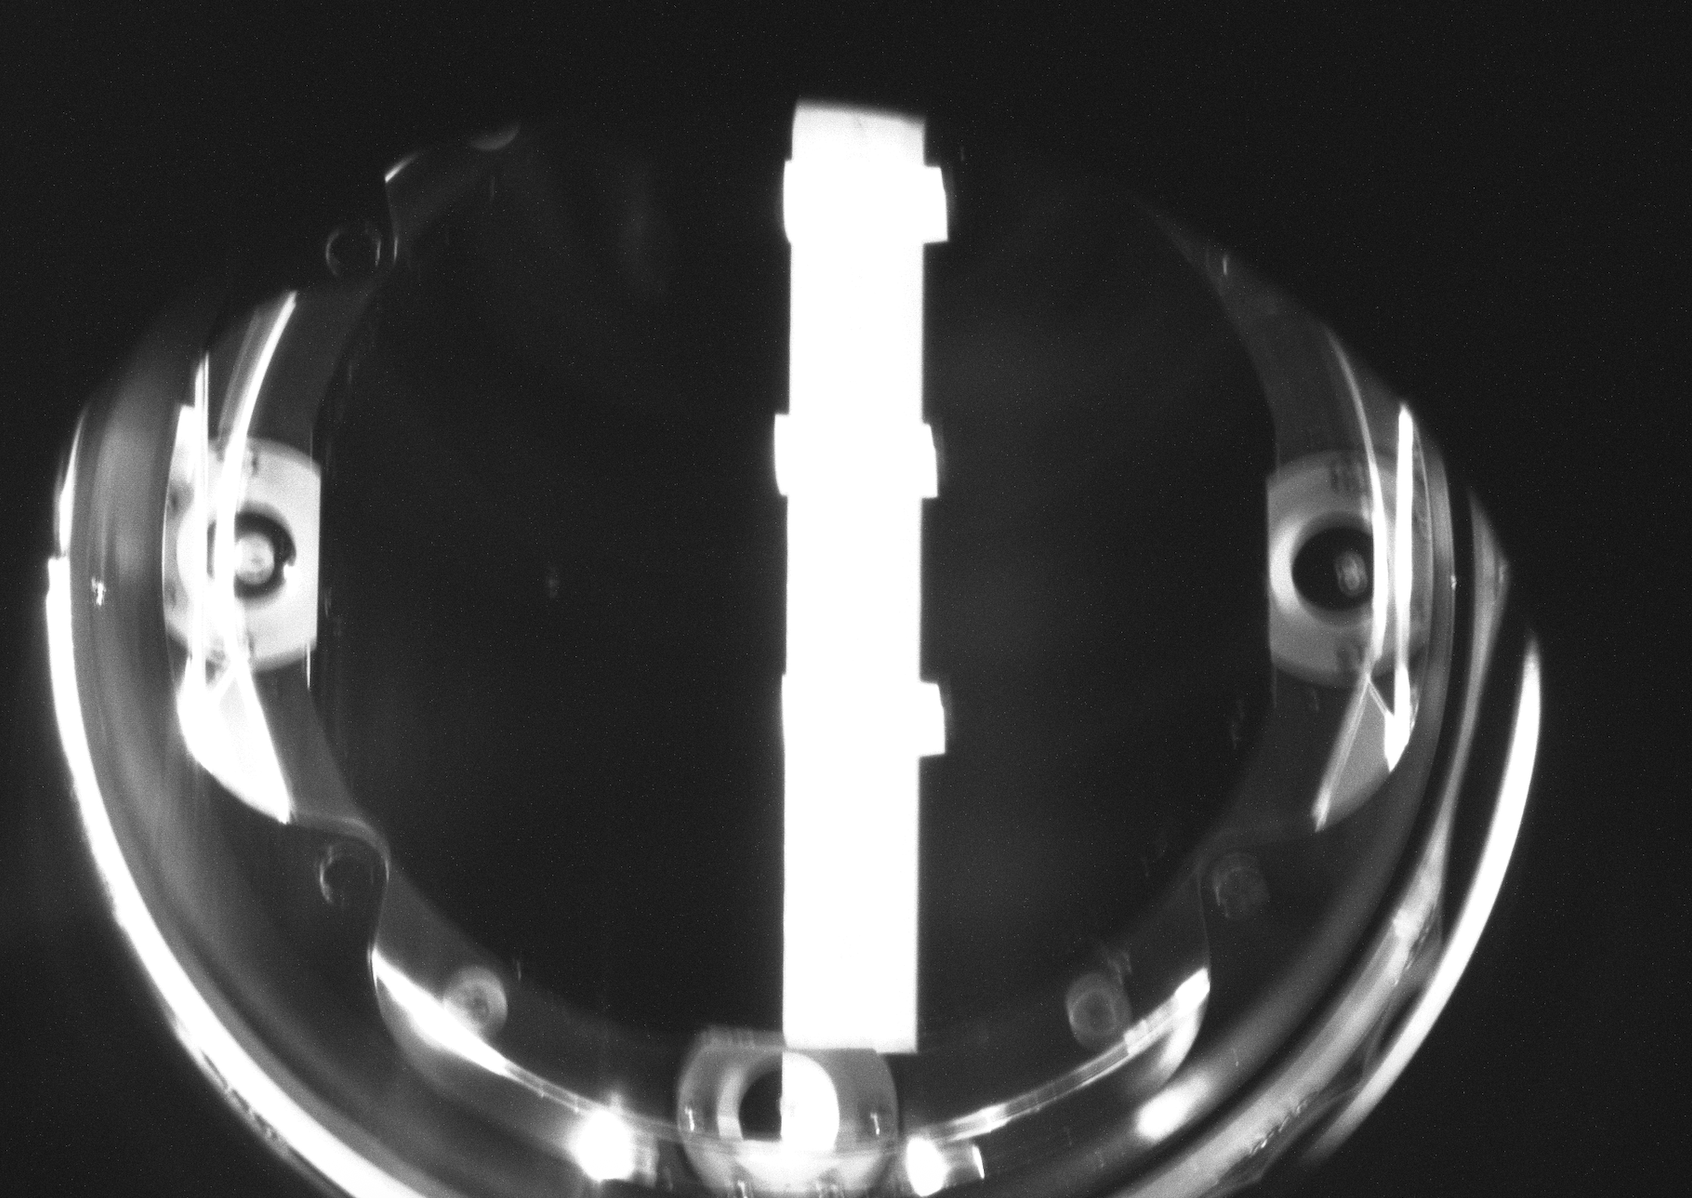
The purpose of this test was to investigate the field of view of the TCam, particularly how much of the area behind ETMX (TMS side) is visible in the TCam images.
By understanding the field of view, we may be able to identify suitable locations for reference markers that could be used to determine the viewing direction of the TCam in the future.
The attached photo shows the 30 cm ruler used in the test.
The white object near the center of the TCam image is the ruler, which was placed at the bottom of the duct on the AR side of ETMX.
Since the ruler's scale markings were not distinguishable in the TCam image, tape markers were attached at 5 cm intervals from the bottom of the ruler.
The upper edge of each tape marker indicates the corresponding 5 cm position.
Uchiyama-san checked the LVDT-ACT coil resistances for the BF GAS. They did not change much.
| Pin | Reference [Ω] | This time [Ω] |
| 1-6 | 217.7 | 229.6 |
| 2-7 | 95.6 | 95.6 |
| 3-8 | 129 | 128.9 |
[Uchiyama, Ushiba(remote)]
We performed the swapping test of ETMX TM H1/H2 actuators and confirmed the problem is at the outside of the chamber.
We performed the swapping test of ETMX TM H1/H2 actuators.
As usual, excitation was injected at 10Hz and we measured TF from excitation signals to TM OpLev PIT.
Figure 1 shows the results.
Left and right pannels show the results when H1 and H2 coil were actuated.
Blue and red represent the measurement before and after cable swapping.
Black line in the left pannels show the reference measured in 2024.
For H1 actuator, red line is higher than blue line by 3dB and comparable with black line, which means actuator efficiency was recovered by swapping the cable.
For H2 actuator, red line is lower than blue line by 3dB, which means actuator efficiency was removed by swapping the cable.
Therefore, we can conclude that the source of actuator efficiency reduction is not at the inside of chamber but at the outside.
Though we haven't confirmed which circuit has a problem, we don't have to reopen the chamber and check the suspension.