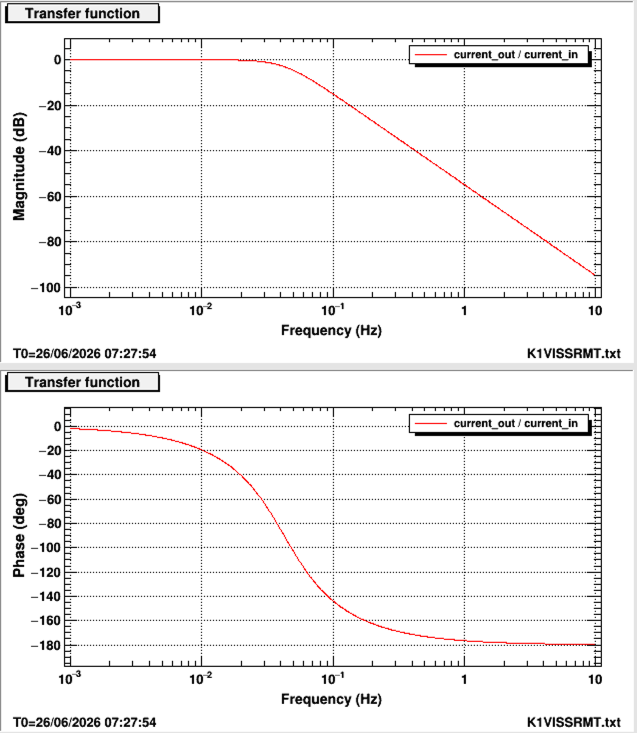
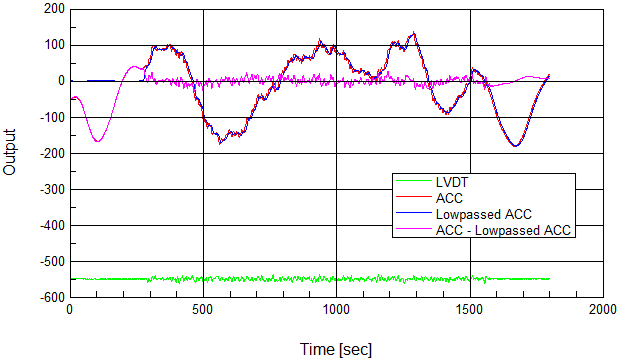
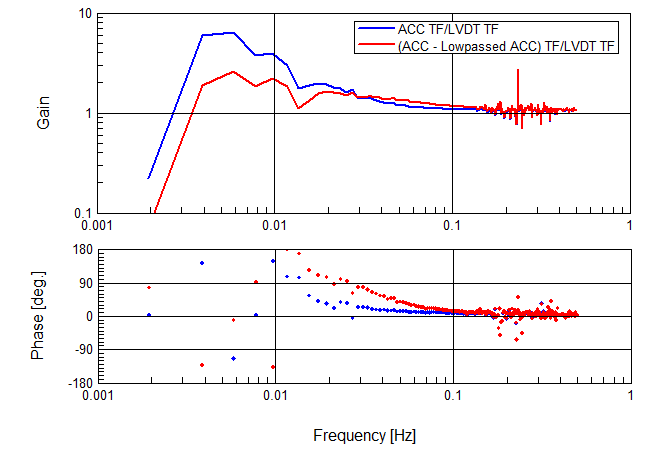
Measured TFs from the IP actuator to the ACCs (or FLDACCs) showed increasing gain toward DC below 70mHz for L and 50mHz for T as reported in klog. It is due to the cradle effect. It is difficult to correct the gain using general servo filters. We are considering whether feedforwarding can reduce the gain at low frequencies. I tried to create ACC L signals compensated by the low-passed signals offline. Plot 1 shows the used low-pass filter. Plot 2 shows time-domain data of LVDT, ACC, and low-passed ACC signals. The IP L was excited with the IP actuator during 300~1500sec. Plot 3 shows the ratio of the LVDT TF and the ACC TF. The gain with compensated signals was smaller than the original, but the phase difference was larger.